Projekt
Remotely Operated Vehicles Training System
Kunde
Underwater Robotics Systems Provider
Anwendungsbereich
Underwater Robotics / Offshore / Inspection and Maintenance / Safety Training
Operational Simulation for Remotely Operated Vehicles (ROVs) with Camera View and Sonar Display
Client Requirements
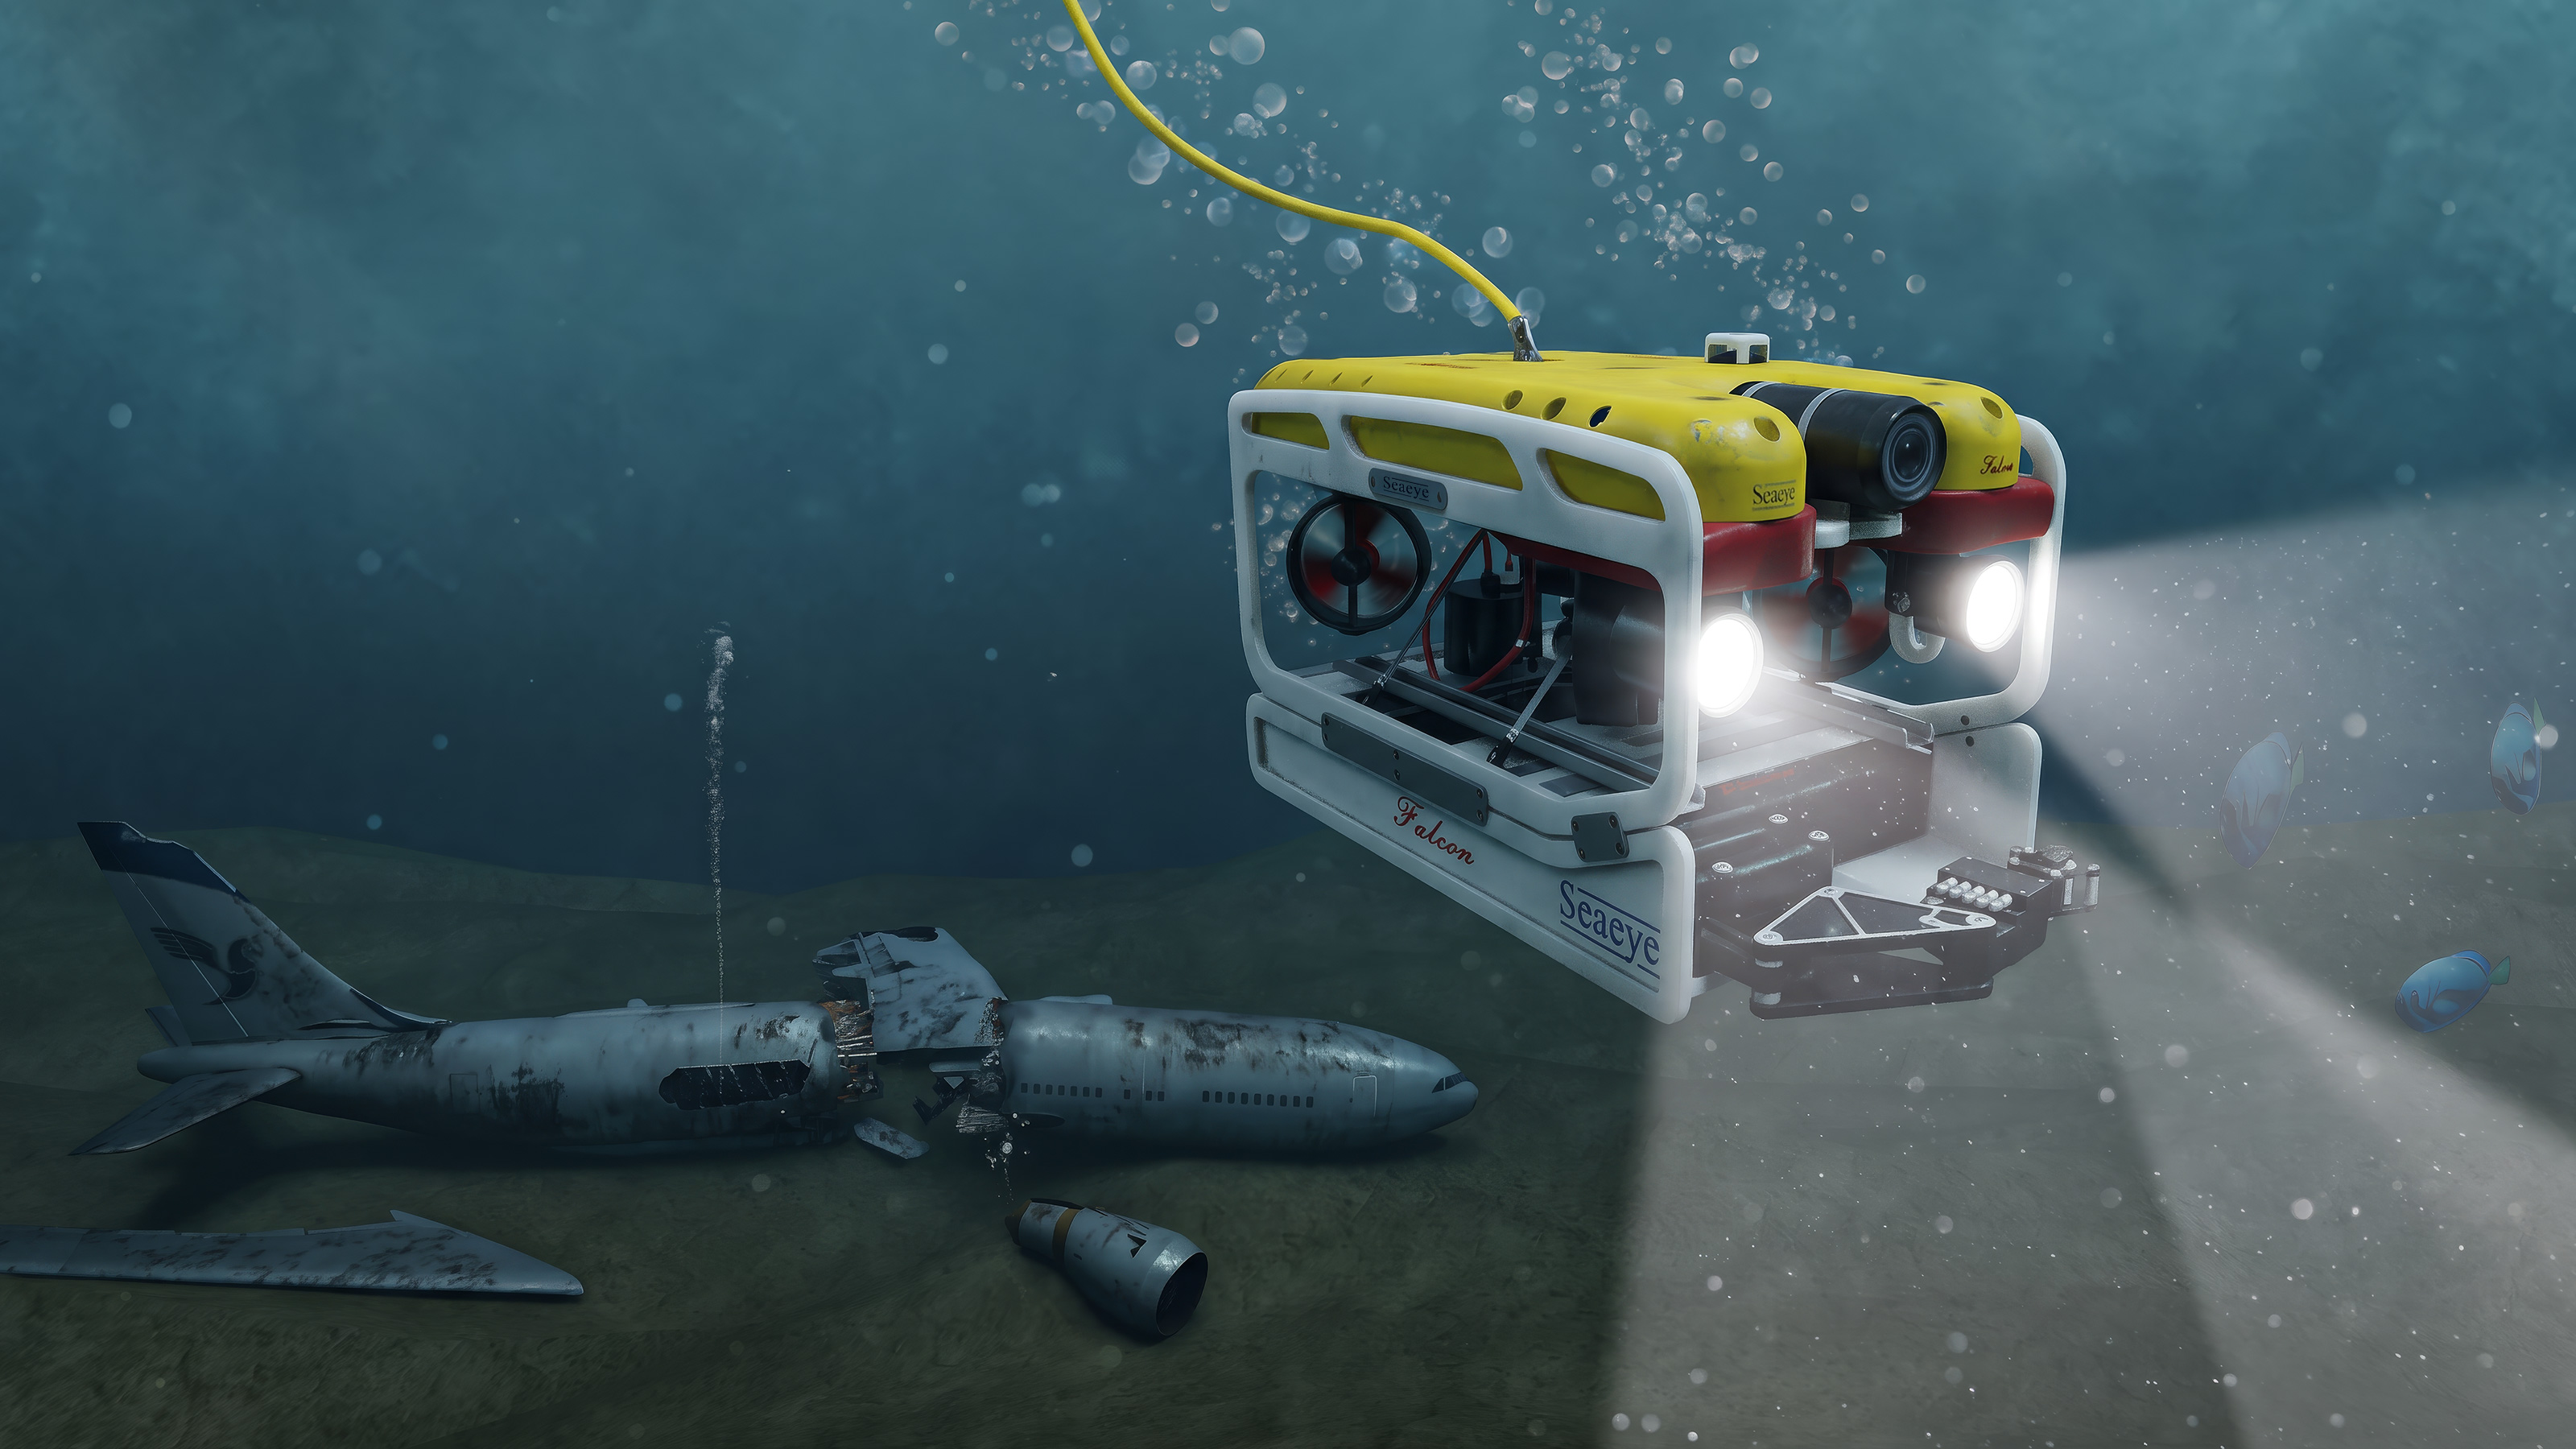
Remote-operated underwater vehicles such as the GNOM and Seaeye Falcon are essential for working in hard-to-reach and hazardous underwater environments, such as during inspections of pipelines, ship hulls, or offshore installations.
Operating these underwater robots requires a high degree of precision and experience. Real-world training is costly, logistically complex, and heavily dependent on environmental conditions. At the same time, operators must be prepared for a wide variety of operational scenarios, often under difficult visibility and current conditions that are nearly impossible to reproduce in a controlled manner during real-world training.
OUR SOLUTION
Immersive Simulation for Underwater Robot Training
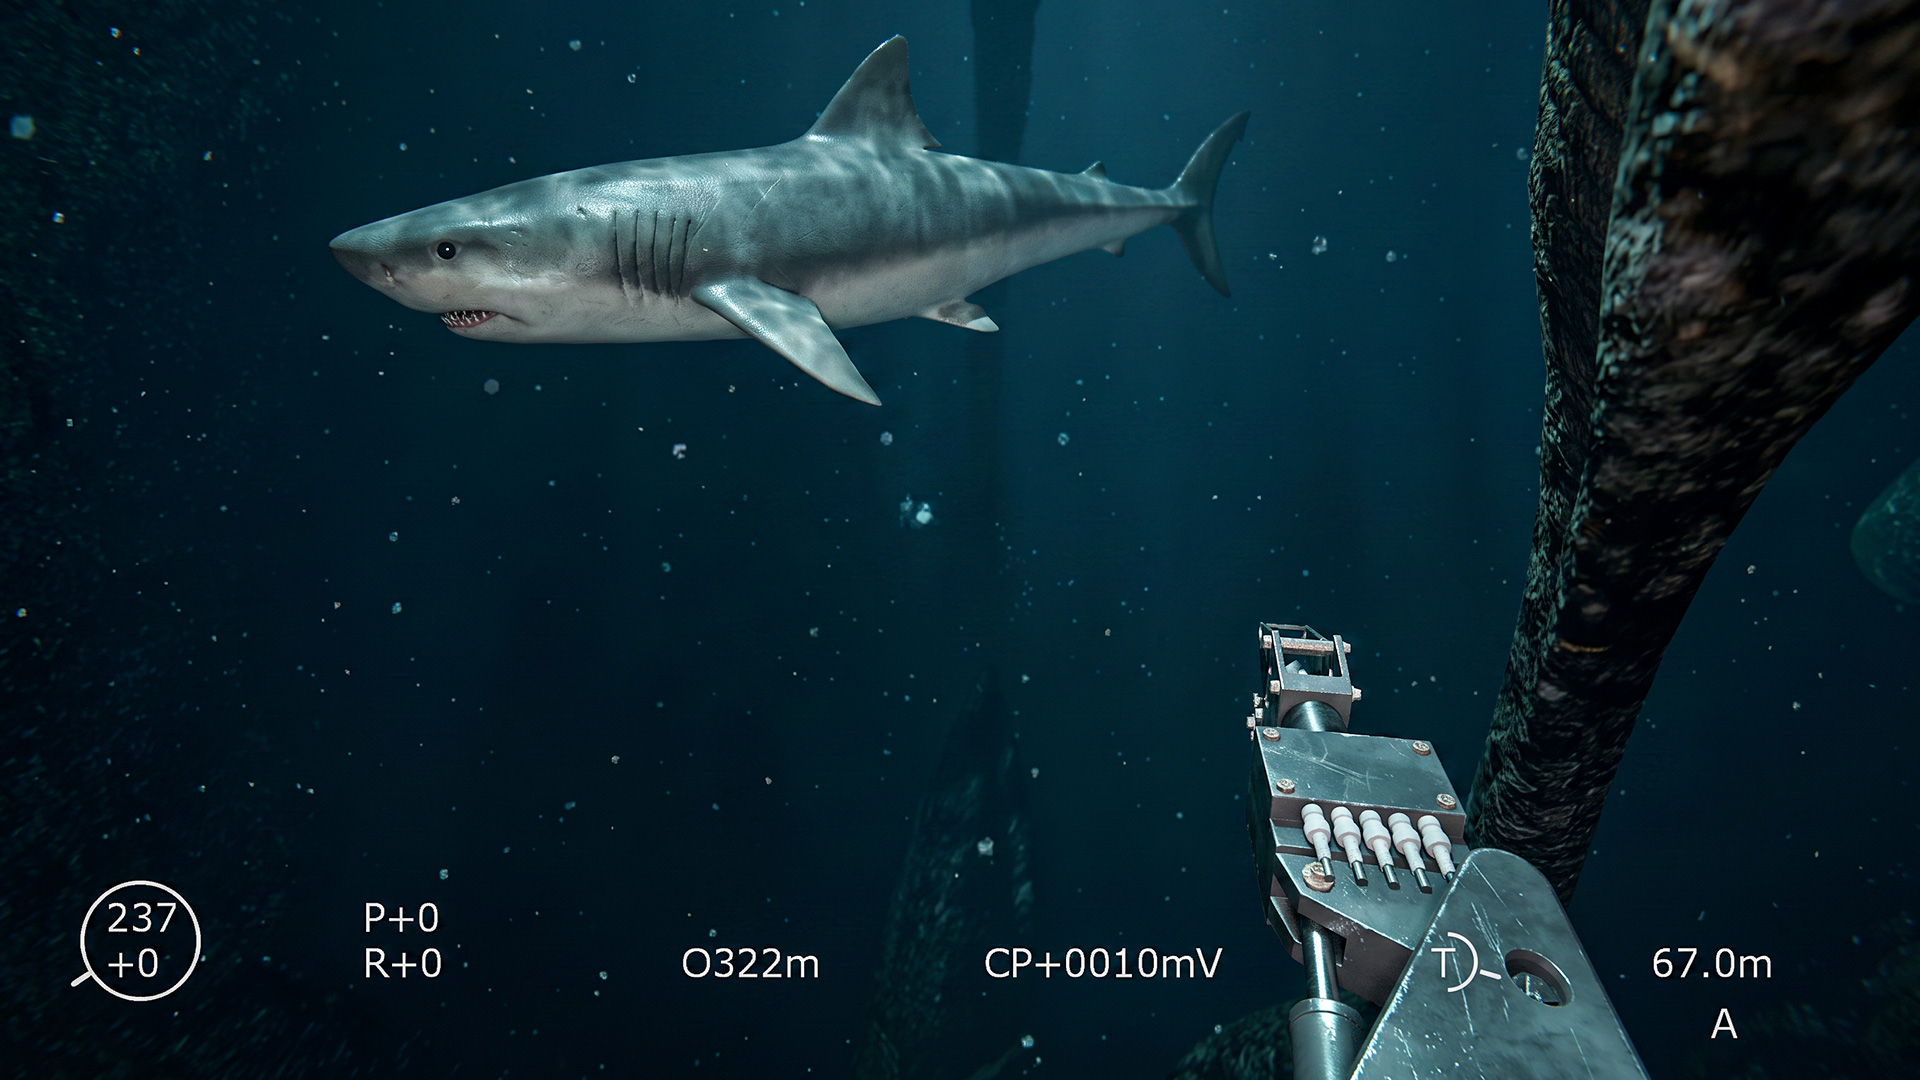
SZENARIS developed an immersive operational simulation for the GNOM and Seaeye Falcon remote-operated underwater vehicles, featuring highly detailed 3D models and realistic physics. Immersion is achieved through two dedicated screens: one for the camera view from the underwater vehicle’s perspective and one for the sonar display with color-coded depth information, exactly as operators experience the system during real-world operations.
Virtual Underwater World with Configurable Scenarios
The integrated Control Center enables training personnel to configure exercises specifically for their needs. Operational environments such as shipwrecks, aircraft wrecks, pipelines, and caves are available for selection. In addition, underwater visibility, current intensity, the type of gripper arm, and the availability of sonar can be individually adjusted. It is also possible to deliberately trigger malfunctions during ongoing exercises to prepare operators for critical situations.
Realistic Physics and Interaction
Operators can control the underwater vehicles in the virtual environment in a realistic manner and safely practice typical tasks such as grasping, maneuvering, and inspecting without risk. The high-quality visualization and the realistic physical behavior of the underwater vehicle, including its grasping function, ensure a high degree of immersion and facilitate the transition to real-world operations.
Efficient, Scalable Training
Regardless of weather, location, or the availability of real systems, the operational simulation enables flexible and infinitely repeatable training.
RESULTS & BENEFITS
Immersive operational simulation for underwater operations without operational risks
Configurable scenarios and malfunctions for targeted training situations
Realistic sonar display and camera view for high practical relevance
Reduced costs and logistical effort compared to real-world training
Faster qualification and greater confidence in decision-making for operators
Preparation for complex and critical underwater scenarios
Interested in a similar solution?
We support offshore companies, inspection service providers, and safety organizations
with mission simulations for diving robots and maritime robotics.